
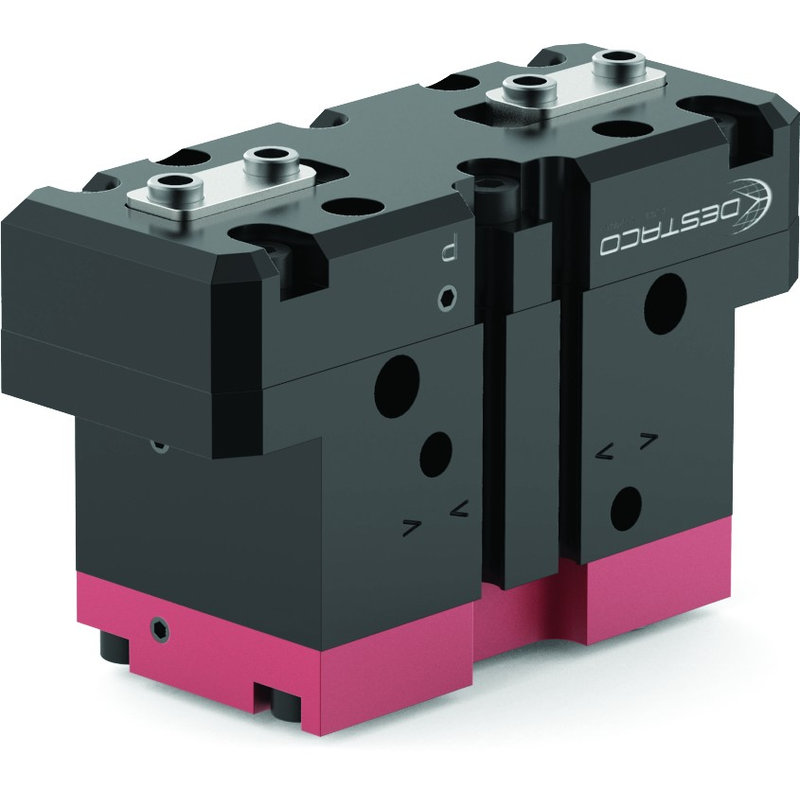
uRDH-4M-L
- Manual Quote
| Weight (lb) | 3.51 |
|---|---|
| Application | Gripping |
| Repeatability (±in) | 0.00012 |
| Bore (in) | 1.07 |
| Grip force (lbf) | 318 |
| Spring-assisted grip force (lb) | 156 |
| Max. vacuum (in. Hg) | 8 |
| Max. finger length (in) | 7 |
| Stroke (in) | 0.79 |
| Finger material | Carbon steel |
| Metric / inch | Metric |
| Accessories | CABL-013|OISA-005|OISA-004|VLVF-008|OHSP-011|OHSN-011|SLKT-416|SLKT-416V|SLKT-363|SLKT-363V|OHSP-011|OHSN-011|OHSP-017|OHSN-017|CABL-010|CABL-013|VLVF-008|VLVF-005|PLFT-037|PLFT-038|PLFT-041|PLFT-042 |
| Brand | Robohand |
| Material | Aluminum alloy |
| Product Type | General industrial 2-jaw pneumaticParallel gripper |
| Includes spindle? | No |
Description
Product Introduction
Designed for high particulate application environments, automotive engine block, gantry systems, and ideal for very heavy part gripping.
Features
- Rugged, multi-purpose, powerful 2-jaw gripper
- Ideal for retrofitting and replacing grippers from other manufacturers
- 7 sizes for small lightweight to very large and heavy part gripping
- High impact resistant with double wedge design
- Shielded gripper to repel metal chips and particulates
- Spring assist option maintains grip in case of air pressure loss
- Purge and scavenge ports for harsh & clean environments
- Sensing up to 2 locations
Markets
- Automotive
- Food and Packaging
- Aerospace
- Consumer Goods